Advancing Transportation Engineering through Multimodal AI, Infrastructure Safety & 3D LiDAR.
I am a Ph.D. Researcher and Fellow in Transportation Engineering at The City College of New York (CUNY), advised by Dr. Yiqiao Li in the AI & Mobility Research Lab. Leveraging an academic background in Computer Science & Engineering, my core research focuses on solving pressing transportation and roadway safety challenges through spatial computing and artificial intelligence.
My research priority is investigating Infrastructure–ADAS interactions and urban crash risk, developing infrastructure-based 3D LiDAR perception frameworks, and introducing automated benchmark pipelines leveraging Vision-Language Models (VLMs) to evaluate vehicle kinematics and roadway conflict mechanisms.
Transportation & Safety
Urban intersection crash risk prediction, multimodal AI fusing computer vision and road geometry, surrogate safety measures, and ADAS-infrastructure readiness (TRB 2026).
3D LiDAR & VLMs
Roadside 3D LiDAR point cloud processing, trajectory-aligned vehicle dimension extraction, and active learning validation pipelines powered by Vision-Language Models.
Human Sensing & XR
Biometric tracking with wearable IoT sensors, video frame engagement analytics, and assistive Augmented Reality for human-centered mobility and cognitive modeling.
Updates
Latest News & Milestones
Recent research breakthroughs, publications, talks, and milestones.
Aug 2026
🎉 Our research paper "Understanding Infrastructure–ADAS Interactions in Urban Crash Risk: A Multimodal AI Approach for Intersection Safety" has been officially accepted for presentation at the Transportation Research Board (TRB) 105th Annual Meeting (2026) in Washington, D.C.!
Spring 2026
🚀 Developed an Accurate Infrastructure-Based LiDAR Framework for bumper-to-bumper vehicle length estimation on highway traffic, integrating Vision-Language Models (VLMs) for automated ground-truth validation with 0.298m MAE (5.2% MAPE).
Jan 2026
👨🏫 Appointed as Adjunct Lecturer / Graduate Teaching Assistant at CCNY Civil Engineering, co-instructing undergraduate engineering problem solving (CE 10000) and assisting Transportation Systems Engineering (CE 32700).
Fall 2025
🏆 Awarded the competitive Grove School of Engineering Ph.D. Fellowship at The City College of New York (CUNY), providing a full tuition waiver and multi-year stipend. Joined the AI & Mobility Research Lab under Dr. Yiqiao Li.
Jun 2024
🎙️ Delivered an invited technical hands-on workshop on "Bridging Reality: Augmented Reality in Modern Robotics" at the IEEE ULAB Robotics and Automation Society SBC.
Research Portfolio
Featured Research Projects
Key investigations spanning transportation safety, 3D LiDAR perception, multimodal AI, and assistive sensing.
TRB 2026 Accepted
CUNY AI & Mobility Lab · Transportation Research Board
Understanding Infrastructure–ADAS Interactions in Urban Crash Risk
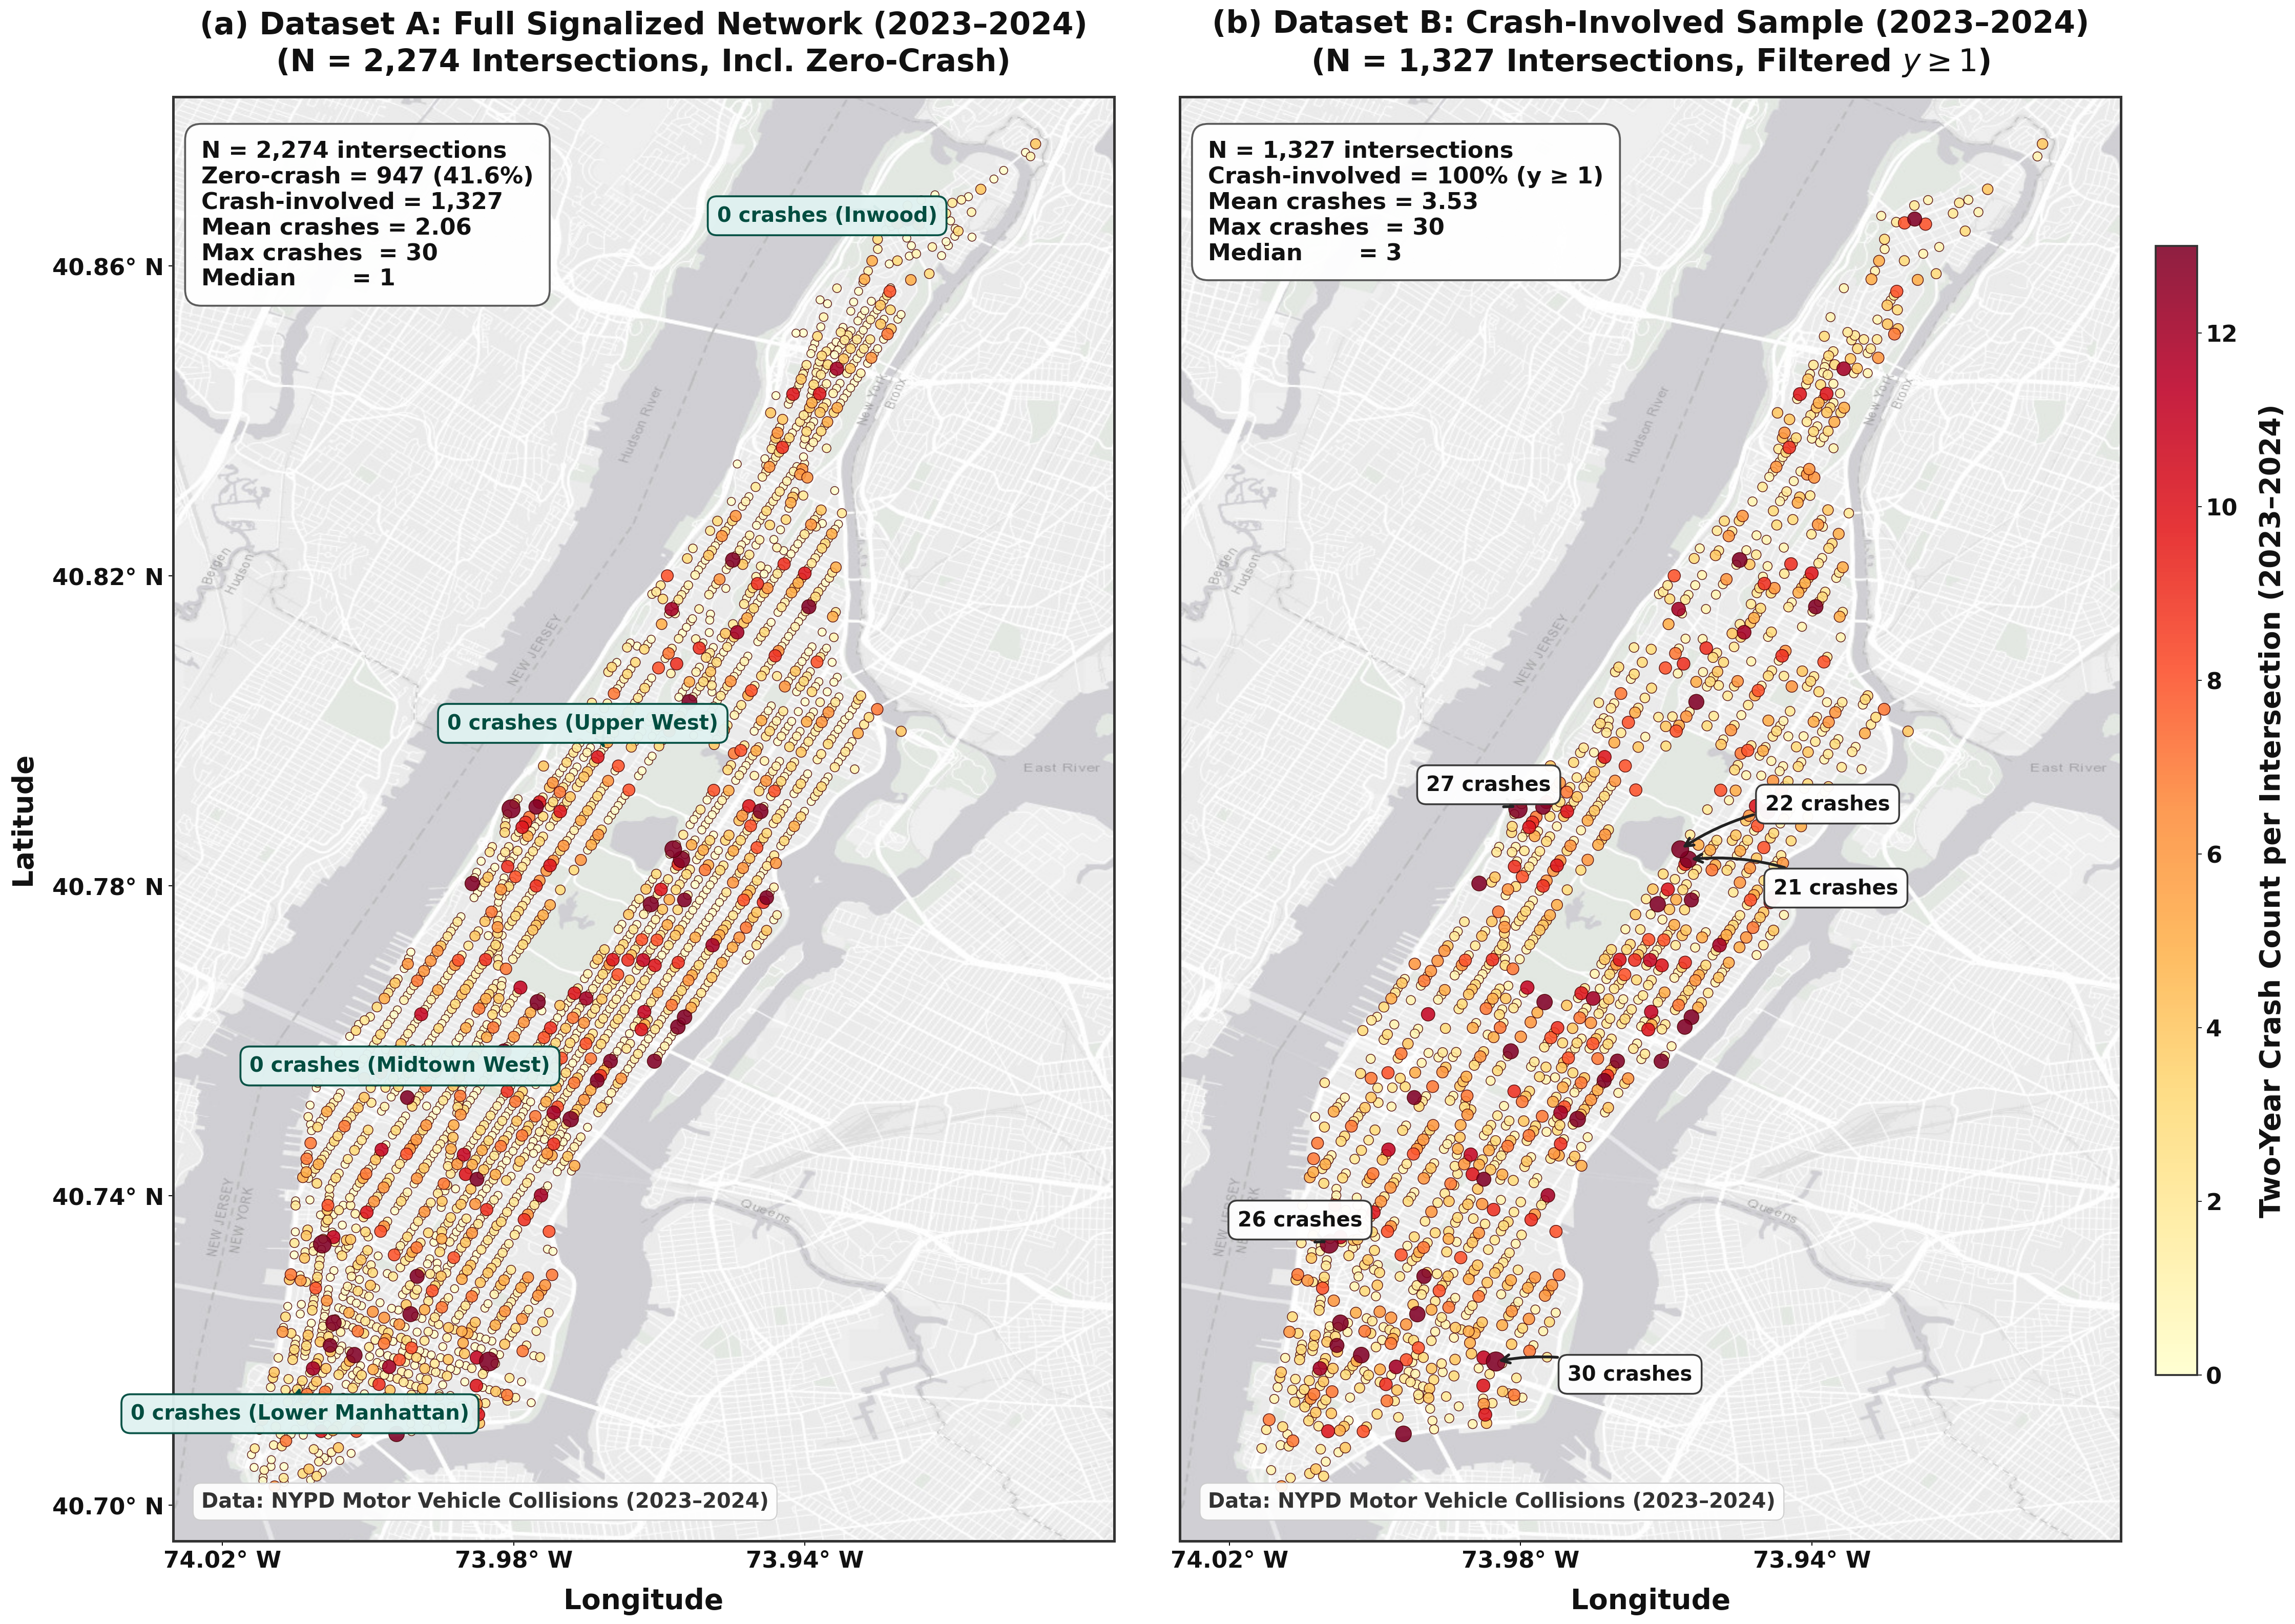
Formulated a comprehensive multimodal AI framework fusing computer vision, road geometry topology, and surrogate traffic safety measures to investigate how ADAS penetration interacts with complex urban infrastructure. Discovered critical non-linear crash risk predictors at signalized and unsignalized intersections across Manhattan.
Acceptance: Accepted for presentation at the 105th Transportation Research Board (TRB) Annual Meeting (2026).
City College of New York (CUNY) · AI & Mobility Lab
Infrastructure-Based 3D LiDAR & VLM Ground-Truth Framework
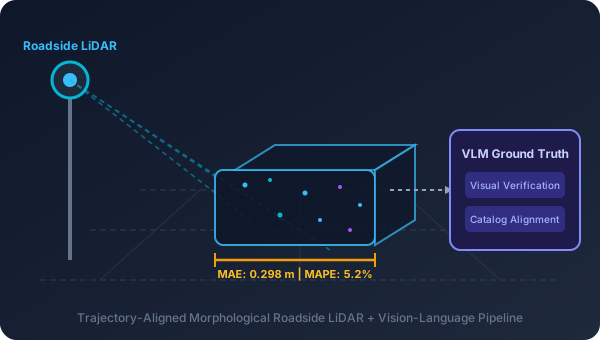
Engineered an end-to-end Trajectory-Aligned Morphological Framework to robustly extract bumper-to-bumper vehicle lengths from roadside 3D LiDAR point clouds. Developed an automated benchmark pipeline leveraging modern Vision-Language Models (VLMs) to query and validate extracted dimensions against OEM manufacturer catalog specifications.
Key Result: Evaluated on complex highway traffic, achieving average MAE of 0.298 meters and 5.2% MAPE across multi-class vehicles.
3D LiDARPoint CloudsVLMsTrajectory ModelingPythonOpenCV
ARise: Multimodal Behavioral Tracking & Assistive AR
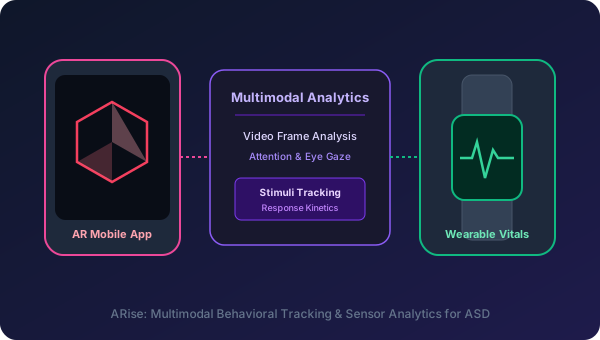
Investigated assistive technology efficacy for children with Autism Spectrum Disorder (ASD). Developed an Augmented Reality literacy application paired with IoT wearable wristband sensors (FitBit/vital tracking) and automated computer vision video frame analysis to capture biometric stimuli responses and learner engagement kinetics.
Impact: Published in MDPI and 2 submitted manuscripts establishing quantitative engagement metrics from combined video frames and wearable physiological vitals.
Real-Time Edge AI for Traffic Lane Rule Violation Detection
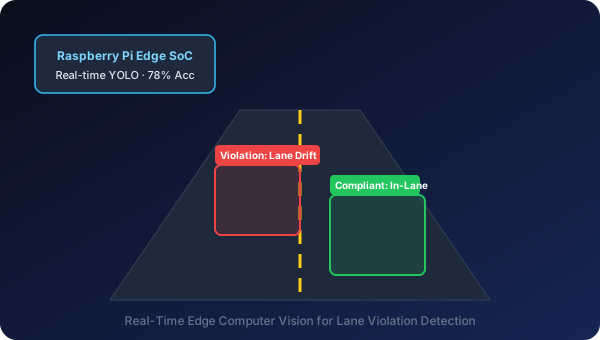
Engineered an intelligent traffic monitoring device on a Raspberry Pi System-on-Chip (SoC) using YOLO computer vision to detect lane rule violations in real-time. Designed spatio-temporal vehicle tracking algorithms deployable directly onto roadside infrastructure cameras.
Performance: Achieved 78% detection accuracy operating in real time under diverse illumination and urban road conditions.
Abstract: Advanced Driver-Assistance Systems (ADAS) offer substantial safety potential, yet their efficacy is strongly moderated by physical urban roadway infrastructure and complex traffic interactions. This research introduces a multimodal artificial intelligence framework that couples computer vision surrogate safety metrics with high-resolution geometric and traffic signal data. We analyze cross-sectional crash risks across complex intersections, revealing non-linear sensitivity factors and establishing infrastructure-readiness guidelines for autonomous and semi-autonomous driving.
@inproceedings{arnob2026understanding,
  title={Understanding Infrastructure--Advanced Driver-Assistance System Interactions in Urban Crash Risk: A Multimodal AI Approach for Intersection Safety},
  author={Arnob, Faed Ahmed and Shang, Bo and Li, Yiqiao and Karimpour, Abolfazl},
  booktitle={Transportation Research Board (TRB) 105th Annual Meeting},
  year={2026},
  address={Washington, D.C., USA}
}
Research Poster2026
An Accurate Infrastructure-Based LiDAR Framework for Precise Vehicle Length Estimation
Faed Ahmed Arnob, Bo Shang, Yiqiao Li
AI & Mobility Research Lab, City College of New York (CUNY)
Abstract: Accurate bumper-to-bumper vehicle dimension extraction is vital for automated classification and digital twin traffic management. We propose a Trajectory-Aligned Morphological Framework using roadside LiDAR point clouds that mitigates occlusion errors. To overcome lack of ground-truth data, we implement a Vision-Language Model (VLM) validation pipeline to benchmark measurements against vehicle specifications, achieving an MAE of 0.298 meters.
@misc{arnob2026accurate,
  title={An Accurate Infrastructure-Based LiDAR Framework for Precise Vehicle Length Estimation},
  author={Arnob, Faed Ahmed and Shang, Bo and Li, Yiqiao},
  howpublished={Poster Presentation, City College of New York},
  year={2026}
}
IEEE Published2020
An Intelligent Traffic System for Detecting Lane Based Rule Violation
F. A. Arnob, A. Fuad, A. T. Nizam, S. Barua, A. A. Choudhury, M. Islam
IEEE International Conference on Advances in Emerging Computing Technologies (ICAECT)
Abstract: Rapid motorization requires automated enforcement of lane discipline. We present an end-to-end edge computer vision device implemented on a Raspberry Pi using YOLO architectures for detecting lane-based rule violations in real-time with an overall 78% accuracy.
@inproceedings{arnob2020intelligent,
  title={An Intelligent Traffic System for Detecting Lane Based Rule Violation},
  author={Arnob, Faed Ahmed and Fuad, Azmol and Nizam, Abu Tahir and Barua, S and Choudhury, A A and Islam, Motaharul},
  booktitle={2020 IEEE International Conference on Advances in Emerging Computing Technologies (ICAECT)},
  year={2020},
  organization={IEEE}
}
Published2020
A Novel Traffic System for Detecting Lane-Based Rule Violation
Md. Azmol Fuad, Faed Ahmed Arnob, Abu Tahir Nizam, Md. Motaharul Islam
International Conference on Advances in The Emerging Computing Technologies
Abstract: Real-time lane discipline violations cause hazardous congestion. This paper outlines an edge-based framework for continuous surveillance cameras using deep convolutional neural networks to identify illegal lane transitions.
Submitted2025
Engagement in ASD Children During ARise Learning Sessions: A Video Frame Analysis Approach
Abstract: Automated engagement quantification in neurodivergent populations is essential for therapeutic education. We introduce a computer vision video frame analytics pipeline to monitor gaze stability, attention focus, and interaction patterns during Augmented Reality educational interventions.
Submitted2025
ARise – an Augmented Reality app for Enhancing Literacy and Learning in Children with ASD
Worked on assistive AR technology for children with ASD. Engineered educational AR app and paired wearable sensor systems to log stimuli.
June 2022 – February 2023
AR, VR, XR, AI, ML, DL Engineer / Trainee
Dept. of Computer Science & Engineering · Indian Institute of Technology (Guwahati & Kharagpur), India
A 6-months training with 1 month internship program fully funded by "The Government of India and Bangladesh Hi-Tech Park Authority (BHTPA)".
Specialized training focused on Augmented Reality, Virtual Reality, Mixed Reality, Extended Reality, Artificial Intelligence, Machine Learning, and Deep Learning.
Developed domain-specific Bangla GloVe word embeddings capable of accurate next-word generation.
3D Point CloudsRoadside LiDARTrajectory ExtractionMorphological FilteringSensor Fusion (LiDAR + Camera)Digital TwinsGIS & Spatial NetworksUnity 3D / AR / XR
Fellowships, academic distinctions, and leadership commendations.
Ph.D. Fellowship — Grove School of Engineering, CCNY
Competitive renewable 5-year fellowship covering full tuition waiver and graduate research stipend (Fall 2025 – Present).
6x Vice Chancellor's Honor List
Awarded by BRAC University for maintaining GPA 3.90 – 4.00 across 6 undergraduate semesters.
Vice Chancellor Certificate of Discipline
Awarded by BRAC University (Residential-46) for high standards of personal discipline and devotion to duties.
2x Dean's List Distinctions
Secured position in the Dean's List for GPA 3.70 – 3.89 in undergraduate computer science studies.
Merit Scholarship (70% Tuition Waiver)
Awarded continuous 70% merit scholarship for 10 semesters based on exceptional academic standing at BRACU.
Fully-Funded International AI/XR Fellowship
Selected for full government fellowship training at IIT Guwahati & IIT Kharagpur in Augmented Reality and Deep Learning.
Stories & Field Notes
From Dhaka's Streets to Autonomous Vehicle Safety
Explore personal essays, research stories, and reflections on transportation engineering, 3D LiDAR perception, and assistive spatial computing by Faed Ahmed Arnob.